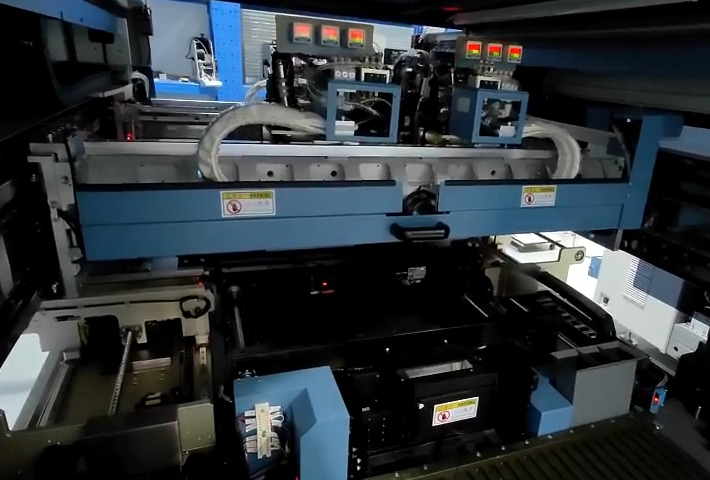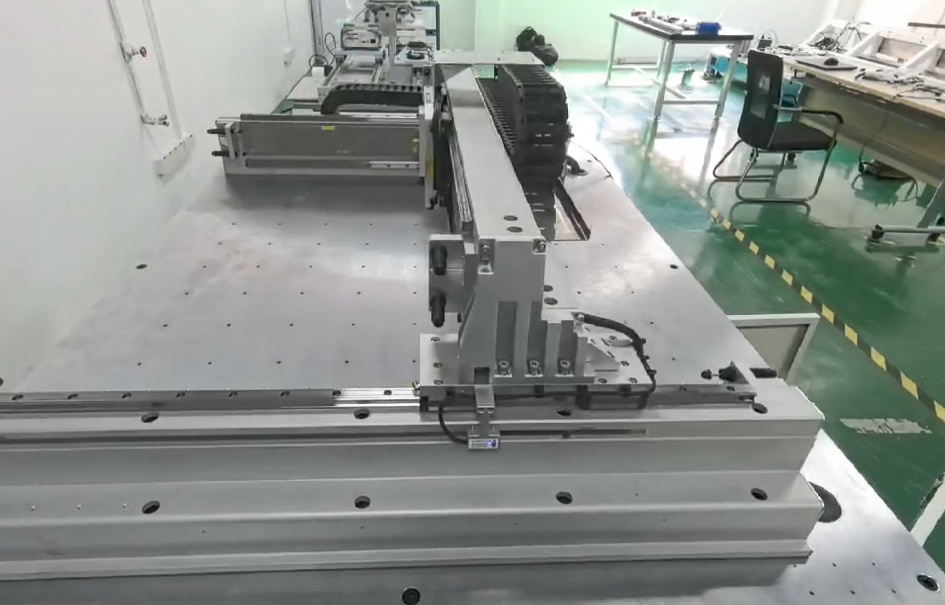
Gantry Synchronization - Semiconductor & Inspection Equipment
HR5 rotary (pulse/EtherCAT) and HD5 direct-drive (pulse/EtherCAT) servos support optional gantry sync function for both rigid and flexible gantry control.
15M high-speed inter-axis communication for real-time triple-loop data exchange.
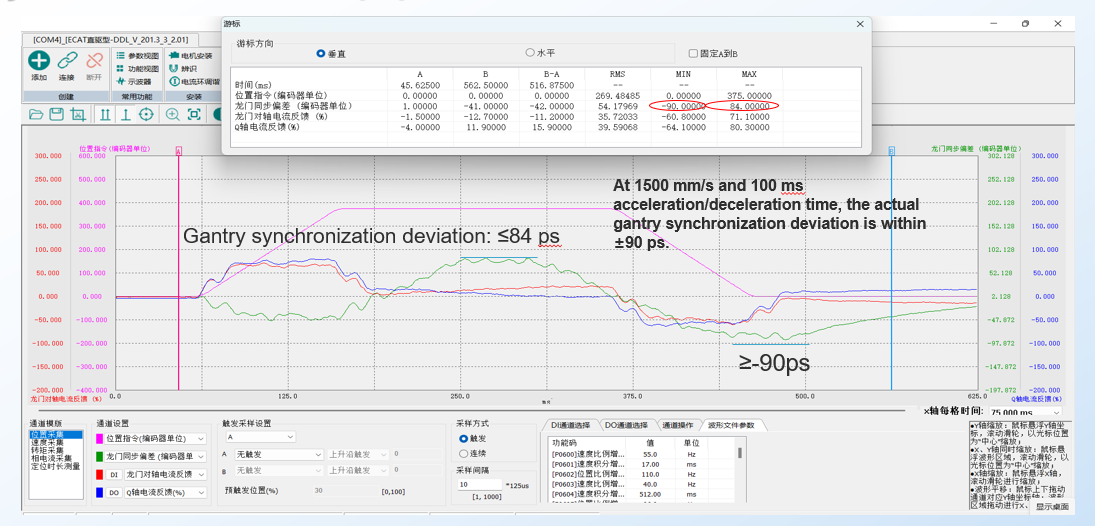
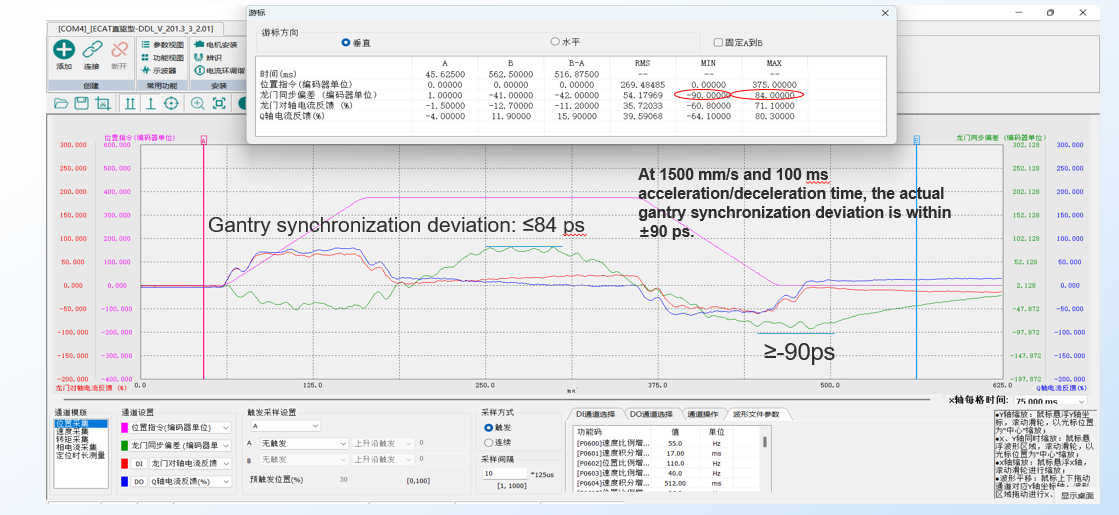
Fast cross-decoupling gantry sync algorithm enables real-time dual-drive synchronization Unique position sync decoupling control continuously detects mechanical deviation for dynamic compensation — meeting higher precision and response gantry.
Paired with linear motors on gantry systems — acceleration up to 4G, speed exceeding 4 m/s.